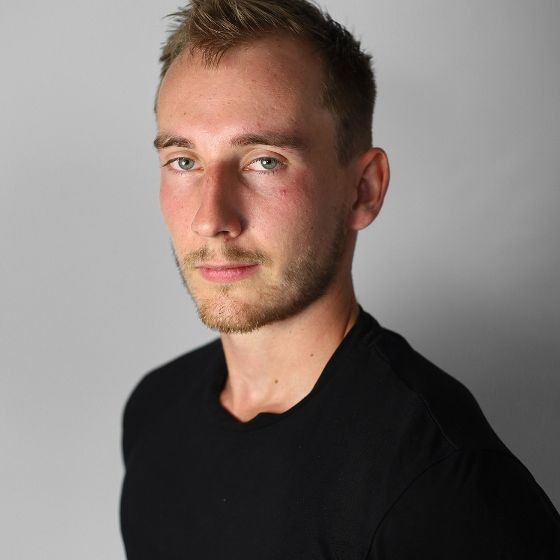
About
I’m a Founding Robotics Engineer at Machenta, working at the intersection of advanced control theory, real-time motion planning, and machine learning.
I own the entire robotics stack, from motor drivers to AI model integration, running on a heterogeneous fleet (UR7e, Franka FR3, Unitree G1, YAMS Pro, Rizon4). That includes the full control stack, real-time collision avoidance, and safety.
My PhD, supervised by Nicolas Mansard and Florent Lamiraux in the GEPETTO team, focused on diffusion-augmented Model Predictive Control (MPC). It was followed by a postdoc in the IMPACT team at CIIRC CTU, where I worked with Josef Sivic and Vladimír Petrík on merging Vision-Language-Action (VLA) models with classical control. This research background is what I now bring into production.
Core expertise: Model Predictive Control (MPC) · Motion Planning · Dynamic Collision Avoidance · Reinforcement Learning / VLA / Diffusion for Robotics · Production-Quality Robotics Software
I graduated from Arts et Métiers and Sorbonne Université, where I specialized in robotics and mechanical engineering.
News
- [05/2026] Moving to London, UK, to join Machenta as Founding Robotics Engineer.
- [11/2025] Moving to Prague, Czech Republic, to start a postdoc at CIIRC CTU.
- [10/2025] Successfully defending my PhD!
- [05/2025] Presenting the paper Collision Avoidance in Model Predictive Control using Velocity Damper in ICRA 2025, Atlanta, USA.
- [12/2024] Coding Week at CIIRC-CTU, Prague for the AGIMUS Project.
- [06/2024] Presenting the paper Model Predictive Control under Hard Collision Avoidance Constraints for a Robotic Arm in UR 2024, New York, USA.
- [06/2024] 2 months Invited Scholar in the Machines in Motion team in New York University
Publications
Fall 2025: Diffusion Augmented Model Predictive Control for Collision Avoidance in Cluttered Robotic Environments. Arthur Haffemayer. PhD thesis. Thesis here.
Summer 2025: Learning-Guided Force-Feedback Model Predictive Control with Obstacle Avoidance for Robotic Deburring. Krzysztof Wojciechowski, Ege Gursoy, Arthur Haffemayer, Sébastien Kleff, Vincent Bonnet, Florent Lamiraux, Nicolas Mansard. Accepted at ICRA 2026.
Summer 2025: Collision-Free Model Predictive Control Warm-Started with Diffusion Model. Arthur Haffemayer, Alexandre Chapin, Armand Jordana, Krzysztof Wojciechowski, Florent Lamiraux, Nicolas Mansard, Vladimír Petrík. Published at Robotics and Automation Letters (RA-L). Paper, video and open-source implementation here.
Winter 2024: Infinite-Horizon Value Function Approximation for Model Predictive Control. Armand Jordana, Sébastien Kleff, Arthur Haffemayer, Joaquim Ortiz-Haro, Justin Carpentier, Nicolas Mansard, Ludovic Righetti. Published at Robotics and Automation Letters (RA-L). Paper here.
Winter 2024: Collision Avoidance in Model Predictive Control using Velocity Damper.
Arthur Haffemayer, Armand Jordana, Ludovic de Matteïs, Krzysztof Wojciechowski, Ludovic Righetti, Florent Lamiraux, Nicolas Mansard.
Published at ICRA 2025.
Paper, video and open-source implementation here.Spring 2024: Model Predictive Control under Hard Collision Avoidance Constraints for a Robotic Arm.
Arthur Haffemayer, Armand Jordana, Médéric Fourmy, Krzysztof Wojciechowski, Guilhem Saurel, Vladimír Petrík, Florent Lamiraux, Nicolas Mansard. Published at International Conference on Ubiquitous Robots (UR). Paper, video and open-source implementation here.